Training worlds for robots.
Physically valid scenes, generated at scale, tested by real robot models, and improved by every failure.
One scene, start to finish.
Generated, validated and simulated end to end. Live coordinates, gripper path and planned route come straight from the simulator.
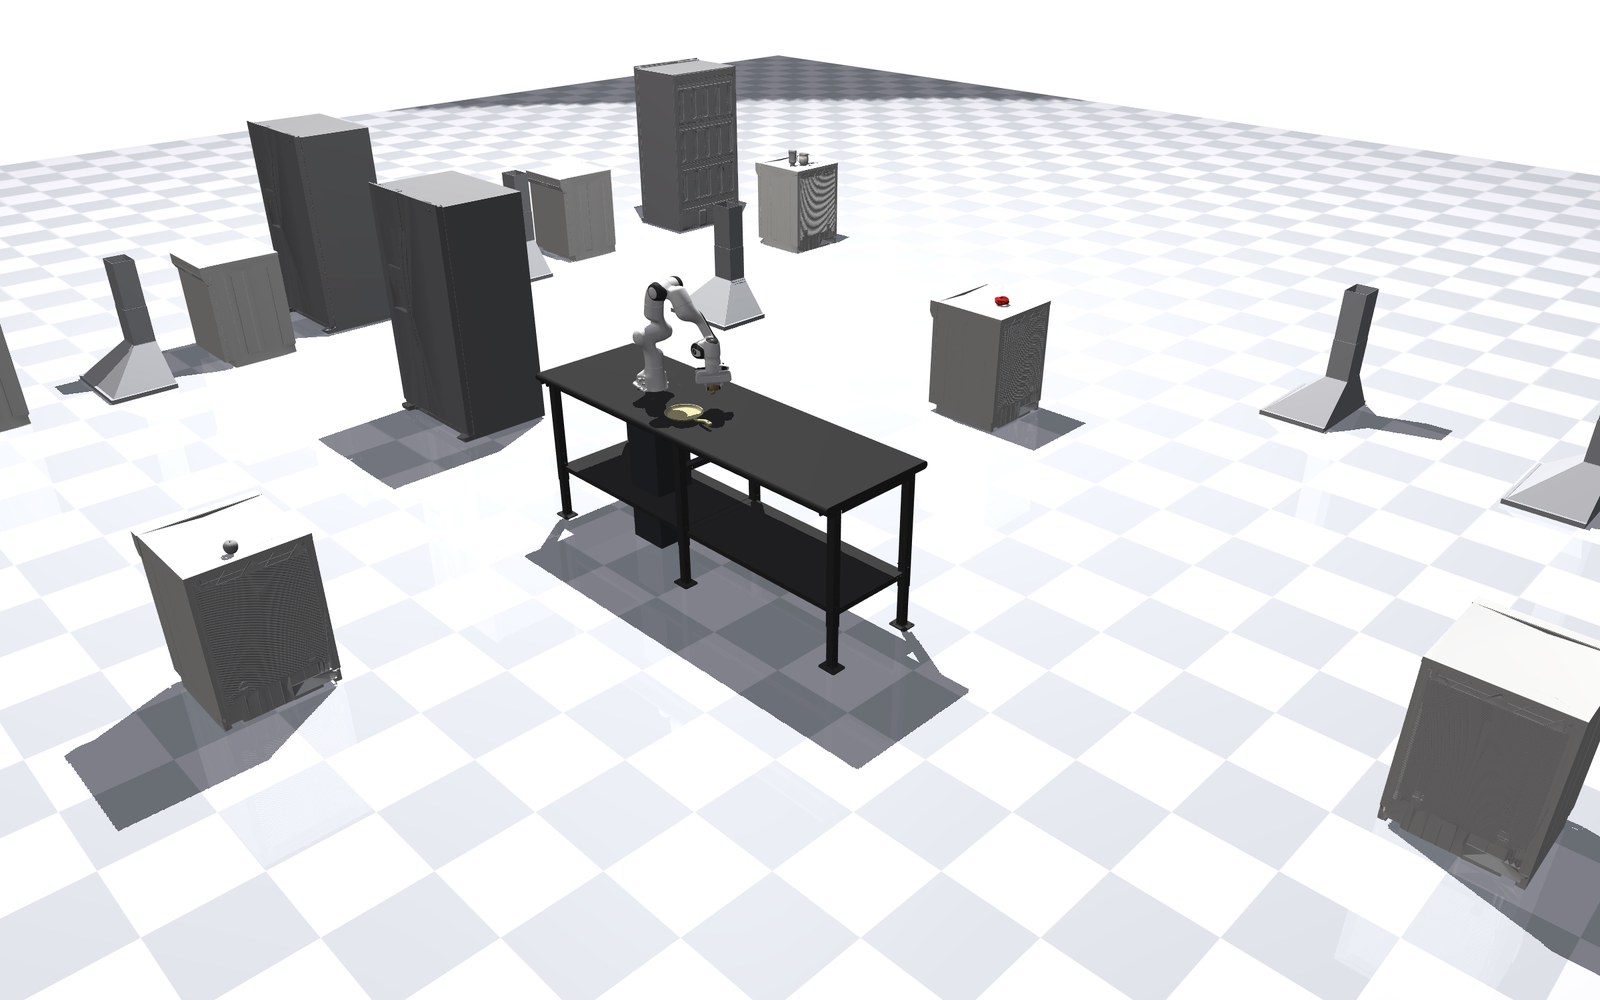
Arm · two-step sort in a kitchen
Franka Panda · 44 objects in the scene · 23 s, real time
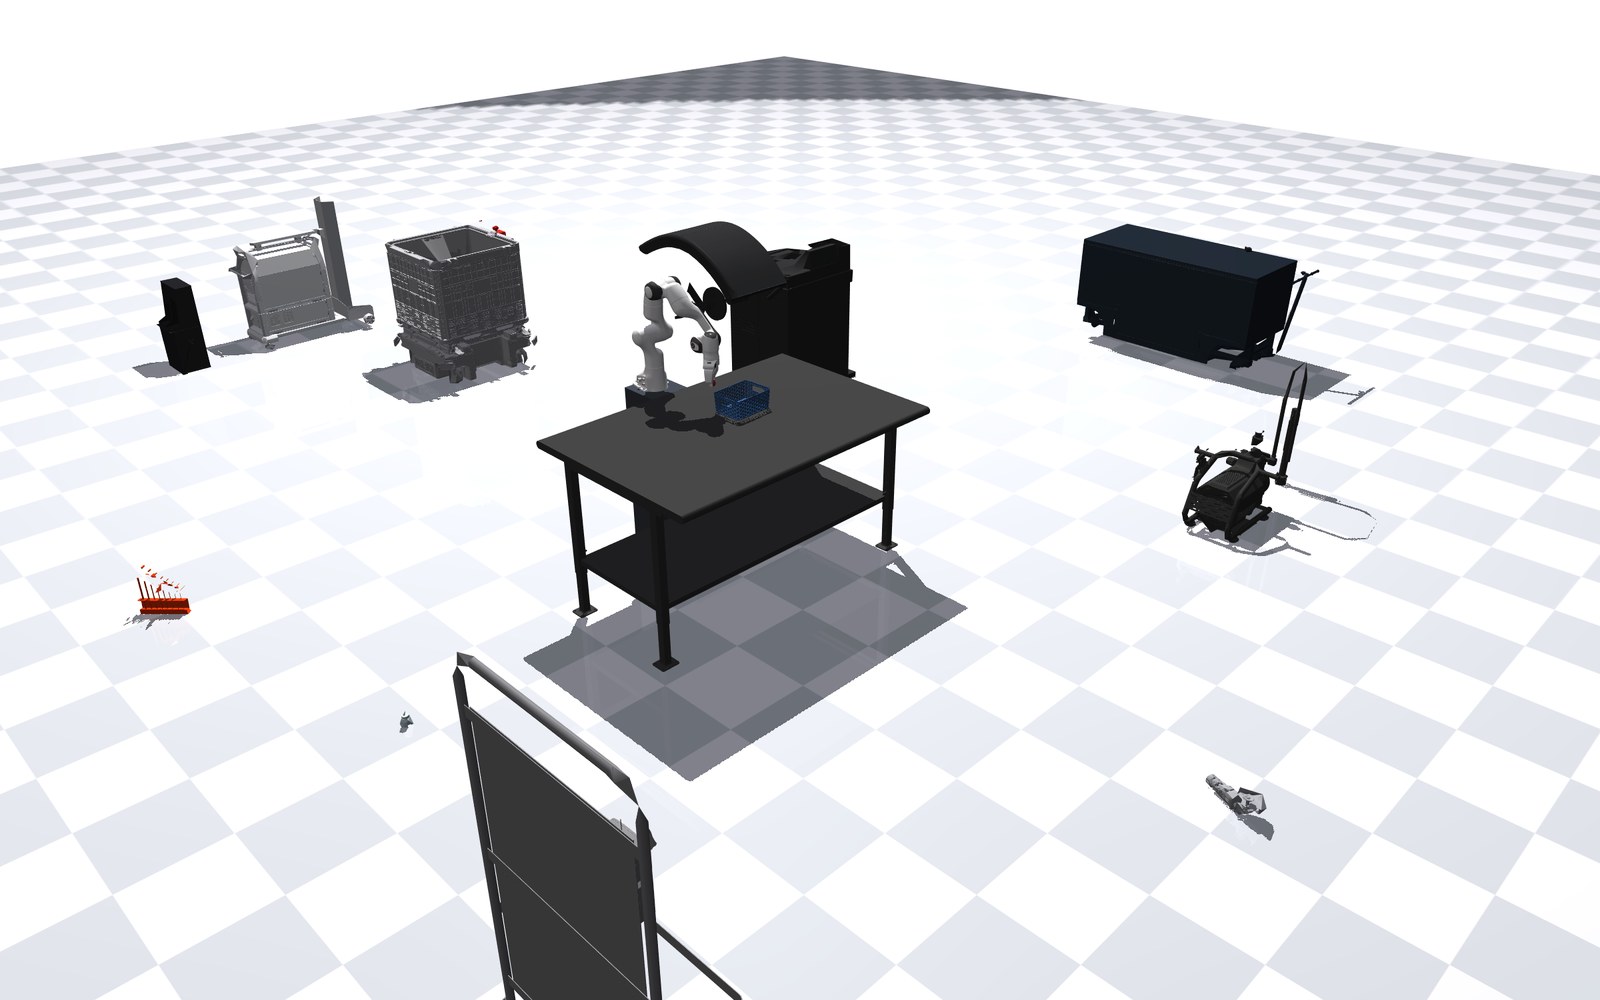
Mobile manipulator · fetch in a warehouse
TidyBot · 5.2 m planned route · 63 objects · 26 s, real time
Under the hood.
Every scene goes through the same pipeline before a robot ever touches it.
Physics-grounded objects
Measured mass, friction and collision meshes. Support surfaces detected from geometry, not bounding boxes.
Constraint-based layout
Intent to exact poses with collision-free sampling under reach, support and clearance constraints.
Physics gate
Every scene is simulated before use. Interpenetration is rejected and impossible requests are explained.
Robot-aware feasibility
Measured workspace maps decide what each body can do. Mobile bases plan their own route with A*.
Failure-driven curriculum
Failures are clustered by cause and regenerated where the policy is weakest.
MuJoCo and USD
Every scene exports to MuJoCo for fast CPU rollouts and to USD for Isaac Sim.
Five tasks, seven environments, any asset.
Every combination, tested.
Robot success per task and environment, over generated scenes, with a scripted controller. No real-robot results yet.
| Task | Tabletop | Warehouse | Hospital | Kitchen | Factory | Auto shop | Office | All |
|---|---|---|---|---|---|---|---|---|
| Pick and place | 10/10 | 9/10 | 7/10 | 10/10 | 10/10 | 9/10 | 10/10 | 93% |
| Stack | 8/10 | 9/10 | 9/10 | 8/10 | 9/10 | 9/10 | 10/10 | 89% |
| Shelve | 7/10 | 9/10 | 7/10 | 9/10 | 8/10 | 7/10 | 7/10 | 77% |
| Place at target | 8/10 | 9/10 | 10/10 | 9/10 | 9/10 | 9/10 | 10/10 | 91% |
| Sort | 9/10 | 8/10 | 10/10 | 7/10 | 8/9 | 7/10 | 9/10 | 84% |